Understand your requirement
Start with the exact bearing and mating-part drawings, fit requirements and approved mounting method. Identify permitted loading/support surfaces and the normal and difficult component range.
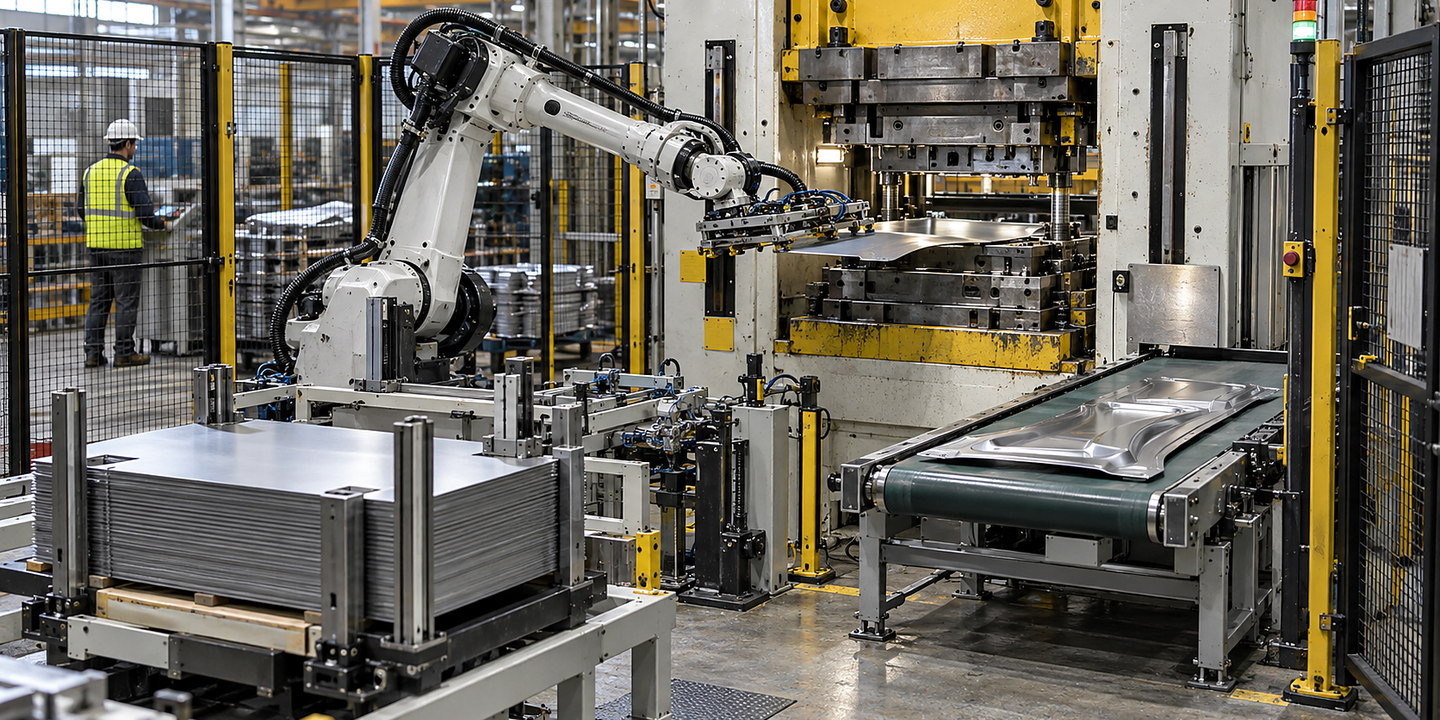
Compare robotic handling, dedicated automation and operator-assisted fixtures using the approved bearing mounting method, alignment, support and assembly checks.
Compare robotic handling, dedicated mechanical automation and operator-assisted fixtures against the same approved bearing mounting method. Each route needs defined part presentation, permitted loading surfaces, alignment and support, process evidence and a controlled response to an abnormal insertion.
Use the route comparison and component and process brief. Operator-assisted assembly still needs a proven location and insertion process; adding a robot does not establish fit quality or replace the required finished-assembly checks.
Plan robotic bearing assembly around your parts, process, cycle time, tooling, recovery and acceptance criteria. Discuss the highest-risk feasibility questions with Oxford Industrial Automation. When you compare solutions, check how each option handles part, product and process variation for robotic bearing insertion & assembly, arrival pattern and presentation and your surrounding line.
Discuss your application

Start with the exact bearing and mating-part drawings, fit requirements and approved mounting method. Identify permitted loading/support surfaces and the normal and difficult component range.
Compare robotic handling, dedicated automation and operator-assisted fixtures using the same parts, alignment/support requirements and assembly acceptance criteria. Focus trials on uncertain handling or insertion steps.
Coordinate presentation, fixture location, insertion tooling, process sensing, unloading and result records. Include operator access, changeover and controlled abnormal-part handling in the proposed scope.
Run agreed normal, difficult and abnormal-result cases, retaining component/tool revisions and process evidence. Define its limits, the separate finished-assembly checks and support/recovery responsibilities.
Typical support: feasibility study, sample trials, cell design, offline build, integration and production ramp-up.
| Approach | Often suitable when | Watch for |
|---|---|---|
| Robotic Bearing Assembly | Robotic presentation and transfer can be assessed alongside a defined insertion method for the intended part range. | Prove location, support and the mounting process separately from robot motion; include complete-cycle and abnormal-result evidence. |
| Purpose-Built Mechanical Automation for a Stable, Very High-Volume Task | A stable bearing and mating-part arrangement can be compared with dedicated feeding, fixtures and process tooling. | Confirm the approved loading surfaces, variation and recovery cases; the automation category alone establishes no rate or fit quality. |
| Operator-Assisted Fixtures where Flexibility or Business Case Does Not Support a Robot Cell | Operator loading and defined fixtures may suit the part mix, order pattern and required flexibility. | Assess location, support, operator tasks and insertion evidence using the same approved method and finished-assembly criteria. |